ÖzetSummary
Dürüst not: Diğer modeller bu fotoğrafları hiç görmeden (zero-shot) ölçüldü. Bizim 2.x karar katmanı ise aynı 1000 fotoğrafın farklı katlarında eğitilip test edildi (5×5 çapraz doğrulama) — yani avantajlı bir karşılaştırma. Dedektörlerin kendisi (aynı açık modeller) değişmedi. Honest note: the other models were measured zero-shot on these photos. Our 2.x decision layer was trained and tested on different folds of the same 1,000 photos (5×5 cross-validation) — so this comparison favours us. The detectors themselves (the same open models) did not change.
1) Aynı 1000 fotoğraf (test1000)1) The same 1,000 photos (test1000)
VehiDE + sağlam araç fotoğrafları. Yakalama = hasarlı fotoğrafta hasar bulma; yanlış alarm = sağlam araçta hasar demek.VehiDE + intact-car photos. Recall = damage found on a damaged photo; false alarm = “damage” on an intact car.
| Model | Macro-F1 | YakalamaRecall | Yanlış alarmFalse alarm | NasılHow |
|---|---|---|---|---|
| ⭐ Çekicin Hasar AI 2.3 (careful)Çekicin Hasar AI 2.3 (careful) | 0.63 | 84% | 15% | 5×5 CV |
| Çekicin Hasar AI 2.3 (fast)Çekicin Hasar AI 2.3 (fast) | 0.62 | 85% | 16% | 5×5 CV |
| Çekicin Hasar AI 2.1 (careful, önceki)Çekicin Hasar AI 2.1 (careful, previous) | 0.63 | 84% | 15% | 5×5 CV |
| Çekicin v1.0 (CarDD YOLOv8s-seg)Çekicin v1.0 (CarDD YOLOv8s-seg) | 0.52 | 82% | 41% | zero-shot |
| shanexf/car-damage-yolo11m-ftshanexf/car-damage-yolo11m-ft | 0.51 | 76% | 14% | zero-shot |
| beingamit99/car_damage_detection (ViT)beingamit99/car_damage_detection (ViT) | 0.46 | 98% | 95% | zero-shot |
| vineetsarpal/yolov11n-car-damagevineetsarpal/yolov11n-car-damage | 0.25 | 70% | 46% | zero-shot |
| tatar01230/car-damage-yolo11ntatar01230/car-damage-yolo11n | 0.18 | 78% | 52% | zero-shot |
Naiscorp Mask R-CNN yalnız 100 fotoğraflık alt kümede çalıştırılabildi (4.4 sn/foto): F1 0.64 · yakalama %83 · yanlış alarm %12 (aynı alt kümede v1.0: 0.53, shanexf: 0.53). Ayrıntılar: benchmark-1000. Naiscorp Mask R-CNN could only be run on a 100-photo subset (4.4 s/photo): F1 0.64 · recall 83% · false alarm 12% (same subset: v1.0 0.53, shanexf 0.53). Details: benchmark-1000.
2) CarDD resmi test seti (374 görüntü) — kutu AP2) CarDD official test split (374 images) — box AP
| Model | AP | AP50 | KaynakSource |
|---|---|---|---|
| Çekicin Hasar AI 2.1/2.3 careful (flip + WBF, int8, telefonda)Çekicin Hasar AI 2.1/2.3 careful (flip + WBF, int8, on the phone) | 62.3 | 78.1 | bizim ölçümour measurement |
| Çekicin fast (int8, telefonda)Çekicin fast (int8, on the phone) | 59.9 | 75.7 | bizim ölçümour measurement |
| CarDD makalesi — DCN+ (ResNet-101, sunucu)CarDD paper — DCN+ (ResNet-101, server) | 60.6 | 78.8 | makalepaper |
| Rabbani & Kosala 2025 — YOLOv11Rabbani & Kosala 2025 — YOLOv11 | 63.34* | – | makale (*metrik tanımı makalede)paper (*metric as defined in the paper) |
| abdullahg7/cardd-yolov8s (v1.0 tabanı)abdullahg7/cardd-yolov8s (base of v1.0) | 58.9 | 75.8 | model kartımodel card |
| shanexf/car-damage-yolo11m-ft (hasar modelimizin tabanı)shanexf/car-damage-yolo11m-ft (base of our damage model) | – | 89.9† | model kartı (†kendi bölmesi, örtüşme olabilir)model card (†own re-split, possible overlap) |
| RF-DETR (Roboflow, Apache-2.0)RF-DETR (Roboflow, Apache-2.0) | GPU defteri hazır | GPU notebook ready | henüz çalıştırılmadınot run yet |
2.3 yalnız karar katmanını değiştirdi; kutuları çizen dedektörler 2.1 ile aynı, bu yüzden CarDD kutu AP'si değişmez.2.3 only changes the decision layer; the box detectors are the same as 2.1, so CarDD box AP is unchanged.
3) Hasar AI 2.3: 1000 yeni fotoğraf ve yeni “kırık parça” başlığı3) Hasar AI 2.3: 1,000 new photos and a new “broken part” head
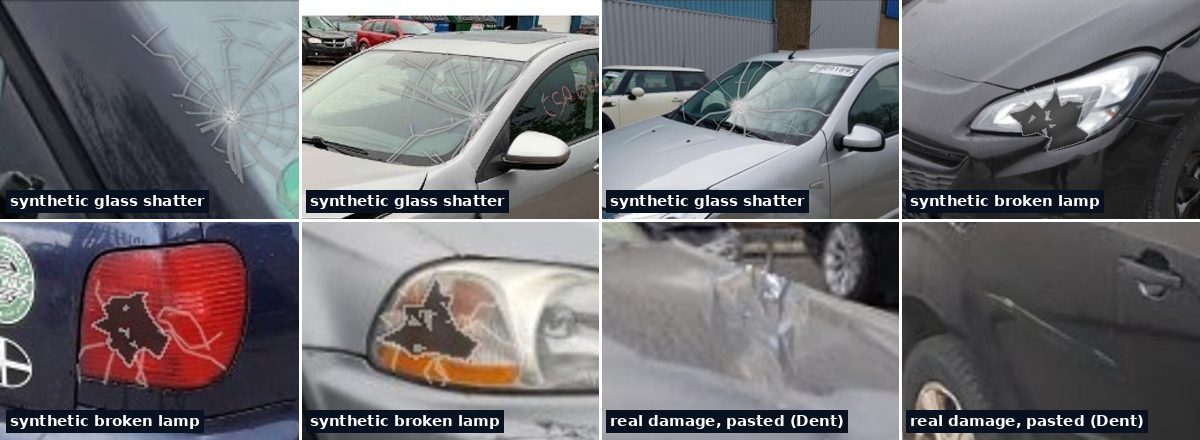
814 gerçek hasar fotoğrafı (DrBimmer, MIT) + 186 sentetik (62 cam kırığı, 62 kırık far/stop, 62 gerçek hasar yamasının başka araca aktarımı). Fotoğrafların %20'si (167) test için hiç kullanılmadan ayrıldı; sentetik yamalar yalnız eğitim kısmından alındı. 814 real damage photos (DrBimmer, MIT) + 186 synthetic (62 shattered glass, 62 broken head/tail lights, 62 real damage patches transferred to other cars). 20% of the photos (167) were held out and never used for training; synthetic patches come from the training part only.
| DrBimmer test (167 foto)DrBimmer held-out (167 photos) | YakalamaRecall | AUROC göçükdent | AUROC çizikscratch | AUROC kırık parçabroken part | F1 kırık parçabroken part |
|---|---|---|---|---|---|
| 2.1 (yayındaki ağırlıklar) · careful2.1 (shipped weights) · careful | 59% | 0.68 | 0.56 | 0.56 | 0.09 |
| ⭐ 2.3 · careful⭐ 2.3 · careful | 59% | 0.67 | 0.59 | 0.79 | 0.51 |
| 2.1 · fast2.1 · fast | 56% | 0.65 | 0.56 | 0.56 | 0.09 |
| 2.3 · fast2.3 · fast | 56% | 0.67 | 0.60 | 0.77 | 0.54 |
| araştırma: kapı da yeni veriyle eğitildi (yayınlanmadı)research: gate also retrained on new data (not shipped) | 69% | 0.68 | 0.61 | 0.79 | 0.79 |
Dürüst okuma. Bu fotoğrafların çoğu ağır kaza: %92'inde kırık/eksik parça, %77'inde göçük var. Böyle bir sette F1 yanıltıcıdır: “hasar varsa hep kırık parça de” kuralı bile F1 0.71 alır. Bu yüzden eşikten bağımsız AUROC'a bakıyoruz: kırık parça 2.1'deki 0.56'dan (kırık lamba skoru, vekil) 0.79'a çıktı (fark %95 GA: +0.10 … +0.35, anlamlı). Göçük / çizik farkı anlamlı değil. Kırık parça eşiği bilerek yüksek (0,50): kesinlik ~%97, yakalama ~%38 (DrBimmer'da) — gerçek dünya VehiDE fotoğraflarında kesinlik yalnız ~%47 (aşağıdaki 2.3.1 denetimine bakın). Yakalama değişmedi, çünkü 1000 fotoğraflık testte yanlış alarmı artırmamak için hasar kapısını 2.1'deki gibi bıraktık. Kapıyı da yeni veriyle eğitmek (son satır) yeni fotoğraflarda yakalamayı %59 → %69 yapıyor ama eski testte F1'i 0.63 → 0.60 düşürüp yanlış alarmı %21'e çıkarıyor. Asıl çözüm: dedektörü bu tür fotoğraflarla GPU'da yeniden eğitmek (defter hazır). 9 tarif denendi; seçim kuralı (eski testte bozulma olmaması) önceden belirlendi. Honest reading. Most of these photos are heavy crashes: 92% contain a broken/missing part and 77% a dent. On such a set F1 is misleading: even the rule “always say broken part when damage is found” scores F1 0.71. So we use threshold-free AUROC: broken part went from 0.56 in 2.1 (broken-lamp score as proxy) to 0.79 (difference 95% CI: +0.10 … +0.35, significant). Dent / scratch changes are not significant. The broken-part threshold is deliberately high (0.50): precision ~97%, recall ~38% on DrBimmer — on real-world VehiDE photos precision is only ~47% (see the 2.3.1 audit below). Recall did not change because we kept the 2.1 damage gate so that false alarms on the 1,000-photo test do not rise. Retraining the gate on the new data too (last row) lifts recall on the new photos from 59% to 69% but drops old-test F1 from 0.63 to 0.60 and raises false alarms to 21%. The real fix: retrain the detector on such photos on a GPU (notebook ready). 9 recipes were tried; the selection rule (no regression on the old test) was fixed beforehand.
1000 fotoğraflık eski test (çapraz doğrulama), careful: 2.3 F1 0.63 / yakalama 84% / yanlış alarm 15% · 2.1: 0.63 / 84% / 15%. Fast: 2.3 0.62 · 2.1 0.62. Old 1,000-photo test (cross-validated), careful: 2.3 F1 0.63 / recall 84% / false alarm 15% · 2.1: 0.63 / 84% / 15%. Fast: 2.3 0.62 · 2.1 0.62.
4) Denetim — Hasar AI 2.3.1 (23.10.2026)4) Audit — Hasar AI 2.3.1 (23 Oct 2026)
Önceki görevi yeniden kontrol ettik (kullanılan 30 beceri). Üç sorun bulundu ve düzeltildi; ağırlıklar değişmedi (2.3.0 ile aynı kararlar, JS ↔ Python 2336 fotoğrafta 0 fark).We re-checked the previous task (30 skills used). Three problems were found and fixed; the weights did not change (same decisions as 2.3.0, JS ↔ Python 0 differences on 2,336 photos).
a) “Kırık / eksik parça” gerçek fotoğraflarda zayıfa) “Broken / missing part” is weak on real-world photos
168 VehiDE fotoğrafını (test1000'den rastgele 120 + sitedeki 48 galeri fotoğrafı) elle etiketledik: cam dışı bir parça yırtık, delik, kopuk, kırık far/stop/sis veya ayna ise “kırık parça”. Sonuç: DrBimmer'daki ~%97 kesinlik taşınmıyor.We hand-labelled 168 VehiDE photos (120 random from test1000 + the 48 site-gallery photos): “broken part” = a non-glass part that is torn, holed, detached, or a broken head/tail/fog lamp or mirror. Result: the ~97% precision seen on DrBimmer does not transfer.
| SetSet | n | gerçektrue | işaretlenenflagged | Kesinlik [%95 Wilson]Precision [95% Wilson] | YakalamaRecall |
|---|---|---|---|---|---|
| fast · ayar seti (120, VehiDE)fast · tune set (120, VehiDE) | 120 | 43 | 51 | 53% [40%–66%] | 63% |
| fast · galeri (48, VehiDE)fast · gallery (48, VehiDE) | 48 | 11 | 17 | 47% [26%–69%] | 73% |
| careful · ayar seti (120)careful · tune set (120) | 120 | 43 | 52 | 48% [35%–61%] | 58% |
| careful · galeri (48)careful · gallery (48) | 48 | 11 | 16 | 38% [18%–61%] | 55% |
AUROC (fast): ayar seti 0.66, galeri 0.71 — DrBimmer'da 0,77–0,79. Eşik değiştirmek, cam kuralı veya 120 etiketle başlığı yeniden eğitmek galeri setinde anlamlı iyileşme getirmedi (yeniden eğitilen başlığın AUROC'u ~0,5): 34 özellik bu sinyali taşımıyor; gerçek çözüm dedektörü “kırık parça” sınıfıyla GPU'da yeniden eğitmek. Düzeltme: etiket artık “olası” olarak gösteriliyor ve maliyette kesin satır değil, “parça değişimi gerekirse” koşullu ek olarak (toplama dahil değil).AUROC (fast): tune set 0.66, gallery 0.71 — vs 0.77–0.79 on DrBimmer. Changing the threshold, a glass rule, or retraining the head with the 120 labels gave no significant gain on the gallery (retrained head AUROC ~0.5): the 34 features do not carry this signal; the real fix is retraining the detector with a “broken part” class on a GPU. Fix: the label is now shown as “possible”, and in the cost box it is a conditional “if a part must be replaced” extra, not in the total.
b) Sentetik fotoğrafların katkısı ≈ 0 (ablasyon)b) The synthetic photos contribute ≈ 0 (ablation)
| Eğitim verisi → DrBimmer test AUROC (careful)Training data → DrBimmer held-out AUROC (careful) | göçükdent | çizikscratch | kırık parçabroken part |
|---|---|---|---|
| full (DrB + all synthetic) | 0.669 | 0.589 | 0.790 |
| no synthetic | 0.670 | 0.589 | 0.787 |
| no glass synth | 0.669 | 0.589 | 0.790 |
| no lamp synth | 0.669 | 0.589 | 0.786 |
| no paste synth | 0.670 | 0.589 | 0.788 |
| synthetic only (no DrB) | 0.678 | 0.563 | – ‡ |
1000 fotoğraflık testte F1: sentetikle 0,631 · sentetiksiz 0,628 · yeni veri olmadan 0,626 (gürültü içinde). Neden: dedektörler donmuş; sentetik pikseller yalnız dedektör yeniden eğitilirse işe yarar. 2.3'teki kazancın tamamı gerçek DrBimmer fotoğraflarından geliyor. ‡ yalnız sentetik veride “kırık parça yok” örneği olmadığı için o başlık eğitilemez.F1 on the 1,000-photo test: with synthetic 0.631 · without 0.628 · without any new data 0.626 (within noise). Why: the detectors are frozen; synthetic pixels only help when the detector itself is retrained. All of the 2.3 gain comes from the real DrBimmer photos. ‡ synthetic photos alone have no “no broken part” examples, so that head cannot be trained.
c) Türkiye maliyeti: piyasa teklifleriyle geriye dönük testc) Türkiye cost: backtest against market quotes
| DurumCase | Bizim (KDV dahil)Ours (incl. VAT) | armut.com teklifleriarmut.com quotes | aralığımızın örtüşmesioverlap of our range |
|---|---|---|---|
| bumper paint (tampon boyama) | ₺2,500 – ₺14,738 | ₺2,500 – ₺10,000 | 61% |
| plastic bumper repair (tampon tamiri) | ₺4,000 – ₺25,764 | ₺4,000 – ₺8,000 | 18% |
| local paint, small scratch (lokal boya) | ₺2,700 – ₺5,400 | ₺2,000 – ₺10,000 | 100% |
| plastic bumper dent repair + paint (tampon tamiri) | ₺4,000 – ₺25,764 | ₺4,000 – ₺8,000 | 18% |
| local paint, small fender scratch | ₺1,800 – ₺3,600 | ₺2,000 – ₺10,000 | 89% |
Önce tampon işleri piyasanın 1,7–3,1 katıydı (plastik tamirde örtüşme %0), çünkü alt sınır ATO azami tarifesinden türetiliyordu. Maliyet modeli 1.1: alt sınır = bağımsız servis teklifi tabanı, üst sınır = ATO azami (yetkili servis). Ayrıca: parça fotoğrafta bulunamazsa “*varsayıldı” işareti; API artık sitedeki ülke bazlı modelin aynısını döndürüyor (cost_estimate, country=TR/DE/GB/US, API 1.6.2).Before, bumper jobs were 1.7–3.1× the market (0% overlap for plastic repair) because the low end was derived from the ATO maximum tariff. Cost model 1.1: low end = independent-shop quote floor, high end = ATO maximum (dealer). Also: a “*assumed” mark when the part is not found in the photo; the API now returns the same per-country model as the site (cost_estimate, country=TR/DE/GB/US, API 1.6.2).
Projeler, makaleler ve veri setleri (linkler)Projects, papers and datasets (links)
YOLO11m, 6 hasar türü; CarDD + sağlam araç negatifleri. Bizim hasar modelimizin (int8 ONNX) tabanı.YOLO11m, 6 damage types; CarDD + intact-car negatives. Base of our damage model (int8 ONNX).
⚖️ AGPL-3.0 (Ultralytics) + CarDD şartları
YOLO11n, 14 parça-hasar sınıfı; parça modelimizin tabanı.YOLO11n, 14 part-damage classes; base of our parts model.
⚖️ Apache-2.0 kart / AGPL-3.0 Ultralytics
YOLOv8s-seg, CarDD; Çekicin v1.0 bununla başladı.YOLOv8s-seg on CarDD; Çekicin v1.0 started from it.
⚖️ CarDD: ticari olmayan
Mask R-CNN R101 (764 MB), Vietnam sigorta fotoğrafları. 100 fotoğraflık alt kümede F1 0.64 (bizim v1.0: 0.53) ama 4.4 sn/foto ve sunucu gerekir.Mask R-CNN R101 (764 MB), Vietnamese insurance photos. F1 0.64 on a 100-photo subset (our v1.0: 0.53) but 4.4 s/photo and needs a server.
⚖️ özel lisans
YOLO11n, 16 parça-hasar sınıfı (Roboflow).YOLO11n, 16 part-damage classes (Roboflow).
⚖️ AGPL-3.0
ViT-Base sınıflandırıcı: fotoğraf başına 1 etiket, “hasarsız” sınıfı yok → sağlam araçta %95 yanlış alarm.ViT-Base classifier: one label per photo, no “no damage” class → 95% false alarms on intact cars.
⚖️ MIT
4.000 görüntü, 6 hasar türü; alanın standart test seti.4,000 images, 6 damage types; the field’s standard test set.
⚖️ ticari olmayan
Gerçek zamanlı DETR; bir sonraki dedektör adayı. Colab/GPU defterimiz hazır (CPU’da eğitilemez).Real-time DETR; our next detector candidate. Our Colab/GPU notebook is ready (cannot train on CPU).
⚖️ Apache-2.0
Büyük görsel-dil modeli + ayrı segmentasyon; %87,3 doğruluk bildiriyor ama sunucu GPU’su gerekir, telefonda çalışmaz.Large vision-language model + dedicated segmentation; reports 87.3% accuracy but needs a server GPU, not on-device.
⚖️ makale
814 gerçek hasar fotoğrafı (göçük, çizik, kırık/eksik parça…) + 998 parça fotoğrafı, poligon etiketli. 2.3’ü bununla eğittik.814 real damage photos (dent, scratch, broken/missing part…) + 998 part photos, polygon labels. We trained 2.3 with it.
⚖️ MIT
Bizim modeller:Our models: cekicin-damage-yolo11m-neg-onnx ↗ · cekicin-damage-yolo11n-onnx ↗ · AI Lab Space ↗ · W&B ↗ · wiki